Matching the Motion Isn't Matching the Physics: Gait Kinetics from Imitation Learning
Motion-only imitation learning can track human gait kinematics well and still get ground reaction forces, center of pressure and joint moments wrong. Adding GRF and CoP to the reward fixes much of it.
Oct 10, 2026
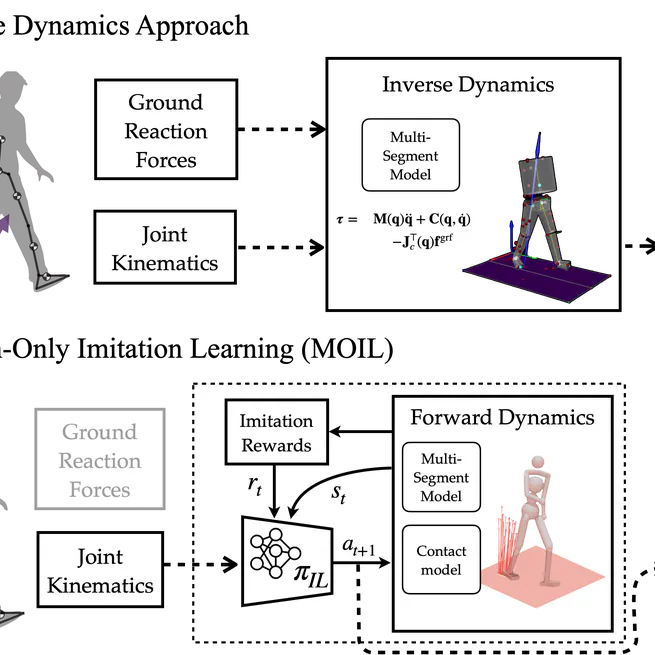
Imitation Learning from Human Motion Alone Does Not Guarantee Biomechanically Plausible Gait Kinetics
Motion-only imitation learning fails to produce biomechanically plausible gait kinetics; kinetics-aware rewards using GRF and CoP are essential for physical consistency in RL-based gait simulation.
Mar 12, 2026